

Run Panel
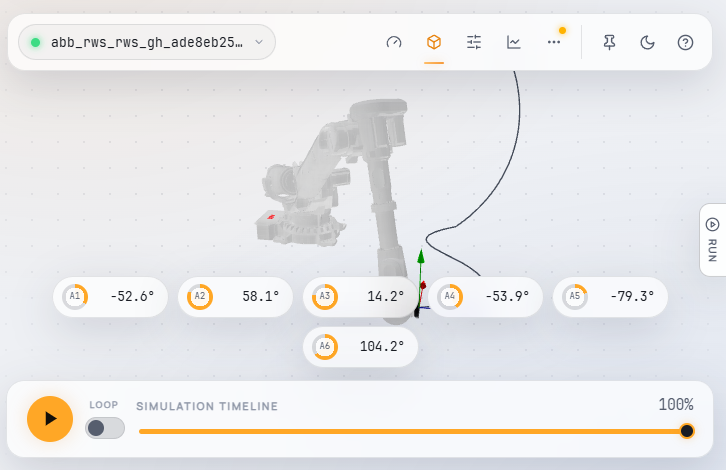
The Run Panel is a drawer on the Server's Visual page: click the Run handle on the right edge of the viewport to open it. It shows everything you need to check and run a program on the currently selected robot without leaving the 3D view — the simulation overview, the generated robot code, the machine controls, and the robot package tools.
Playback stays with the dock at the bottom of the viewport: play/pause, loop, the speed badge on the play button (1×, 2×, 4×, 8×), and the simulation timeline slider.
Simulation#
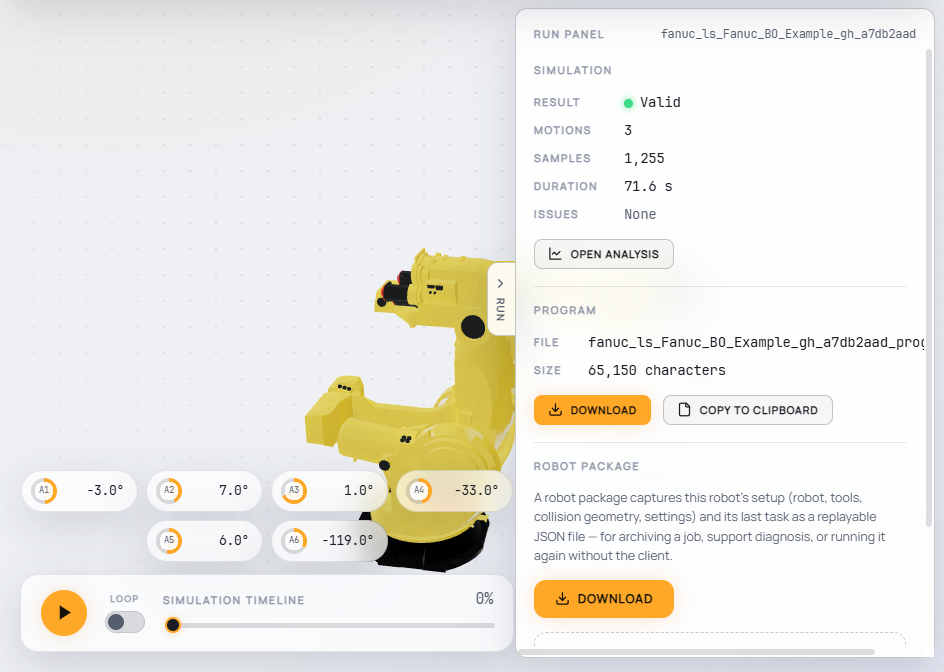
An overview of the last task simulated for the selected robot:
- Result — whether the simulation is valid.
- Motions / Samples / Duration — the size of the toolpath and its estimated cycle time.
- Issues — collisions, out-of-reach targets, singularity regions, and axis alarms found by the simulation. Open Analysis jumps to the Analysis page for the full graphs and issue navigation.
Program#
The robot code generated for the current task, with its file name and size. The file extension matches the driver — e.g. .src (KUKA KRL), .mod (ABB RAPID), .script (UR), .ls (FANUC). Download saves the program to the machine you are browsing from; Copy to Clipboard copies the code text. Drivers that generate several files – e.g. a program plus its data file – list them all, with one Download per file.
Controller Upload#
For a KUKA KSS driver whose KSS Version setting targets iiQKA.OS 2, the panel shows the upload status, the instances found on the controller and an Upload button that sends the generated program directly to the controller (DeviceManager, port 443). The connection values – address, instance, login, target folder – are edited on the Settings page in the Controller Upload section, which also offers List Instances (pick one with Use) and its own Upload button. With Auto Upload enabled, every simulation of an execute-type task uploads the program automatically. Taking control of the controller (SPOC) may require a confirmation on the pendant; an upload waits for it for up to 30 seconds.
Machine#
This section only appears for realtime drivers — KUKA mxAutomation, Universal Robots realtime, NEURA realtime, ABB Robot Web Services, and KUKA Sunrise in its Online execution mode (Run only, no override). Offline code-generation drivers have no machine to moderate, so the section is hidden.
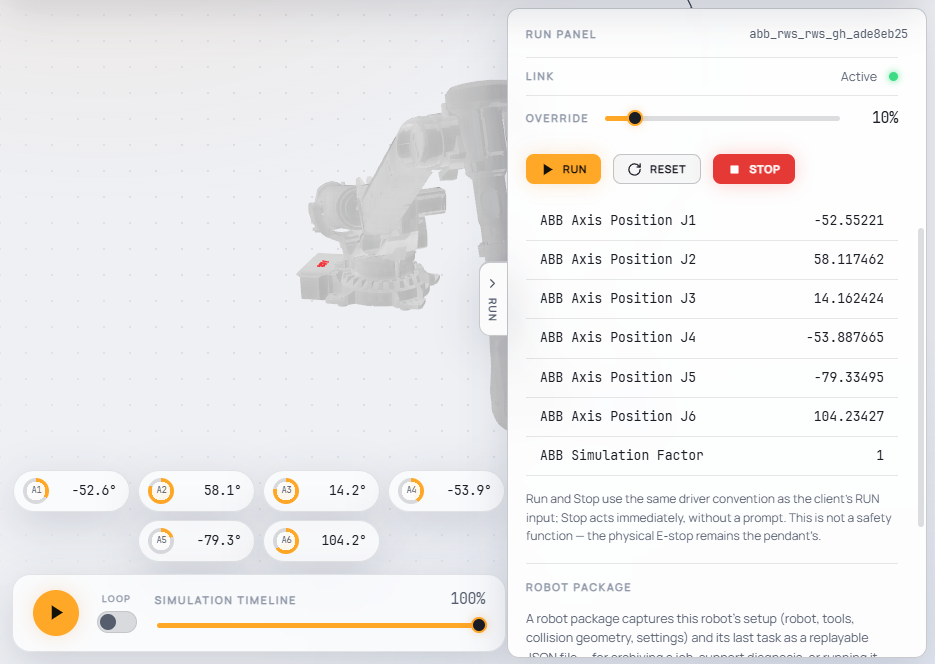
- Link — whether the controller is reporting: Connected while it reports, No reply while Run is on and nothing is heard from it, Not connected otherwise.
- Override — the speed override (OV) as a percentage. When nothing has set an override yet, the console sets it at a deliberately slow 10%, so a first run never launches at full speed.
- Move Enable (KUKA mxAutomation only) — the MOVE_ENABLE gate, shown as the robot reads it: off until something switches it on. Switching it off decelerates and holds the robot; it moves on once Move Enable is on again. With Run on and Move Enable off, the robot does not move.
- Run — a switch. Switching it on hands the loaded program to the machine and starts execution; because the robot will physically move, it asks for confirmation first, and it cannot be switched on without a loaded program. Switching it off stops the drive at once, without a prompt; the exact behavior is driver-specific (e.g. a controlled deceleration on UR, closing the mxAutomation link on KUKA, stopping RAPID execution on ABB). If the program could not be sent (e.g. no current position from the robot, no connection), the panel shows why. It has the same semantics as enabling RUN on the client component: the Run variable is set and the loaded task is handed to the driver again. Applying settings on the Settings page simulates the loaded program again; it only goes to the robot again while Run is on. With the driver's Streaming Mode set to Queue, a new program is run after the ones already queued instead of replacing the running one.
- Reset — sends an error-reset pulse to the driver (KUKA mxAutomation execute-reset, NEURA error reset, ABB RWS program pointer back to
main). In the Queue streaming mode it also drops the programs queued but not yet running (KUKA mxAutomation, ABB RWS, UR RT, KUKA Sunrise). Shown only for drivers that support it.
Below the controls, the driver's own status variables (mxA …, UR …, NEURA …, ABB …, Sunrise …) are listed live — the same values the Settings page's variable view shows.
The machine controls are plain UI over the same well-known control variables (Run, OV, MoveEnable, Reset) that the client components use, so the console and a connected client compose: a program started from Grasshopper can be stopped from the panel and vice versa.
⚠️ Switching Run off is not a safety function. The physical E-stop remains the teach pendant's — never rely on a browser button to make a cell safe.